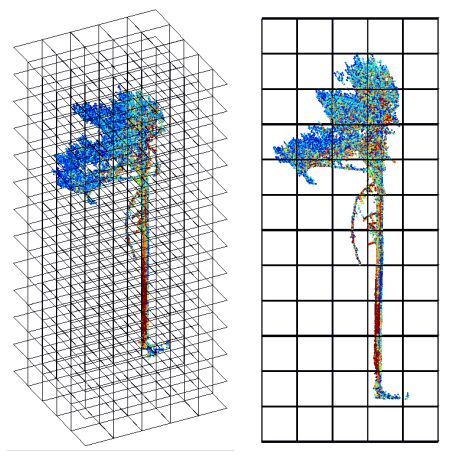

LIS Voxel
LIS Voxel provides tools for transforming point cloud data into regular 3D voxel representations and analysing the spatial distribution of points within them. The package supports statistical summaries, point counts and interception ratios for individual voxels, providing a volumetric alternative to purely surface-based analysis. Typical applications include analysing vegetation structure through vertical and horizontal point distributions, quantifying canopy occupancy and density, comparing structural differences between datasets, and deriving voxel-based metrics for forestry, ecological analysis and other applications where the internal 3D structure of a point cloud is important.
Tool: Create Voxel System
| Features |
|---|
| • creation of a voxel system to be used in other tools for voxel-based analyses |
| • different methods to specify extent and voxel size |
| • voxel size can differ in xy und z |
| Applications |
|---|
| • preparation of voxel-based analyses |
Tool: Point Cloud to Voxel Shapes
| Features |
|---|
| • conversion of a voxelized point cloud to a 3D polygonal shapes representation |
| Applications |
|---|
| • visualization of voxels as 3D polygonal shapes layer |
Tool: Voxel Point Cloud to Grid Collection
| Features |
|---|
| • conversion of a voxelized point cloud into a grid collection voxel representation (grid stack) |
| Applications |
|---|
| • visualization of voxels as a voxel cube |
Tool: Voxelize Laser Penetration
| Features |
|---|
| • creation of a voxelized representation of each laser beam based on a given voxel system |
| • analysis of the voxel - laser beam intersections by tracing each laser beam through the voxel system |
| • computation of incoming and intercepted rays for each voxel |
| • calculation of a plant area index (PAI) |
| • output attributes per voxel: number of incoming rays, number of intercepted rays, penetration ratio, plant area index (PAI), flag for voids |
| Applications |
|---|
| • voxel-based analysis of point clouds |
| • vegetation analyses (density/transparency) |
| • filled and empty space analyses |
Tool: Voxelize Laser Penetration (RDBX)
| Features |
|---|
| • creation of a voxelized representation of each laser beam based on a given voxel system |
| • analysis of the voxel - laser beam intersections by tracing each laser beam through the voxel system |
| • works directly on a set of registered RDBX point cloud files |
| • output attributes per voxel: number of incoming rays, number of intercepted rays, penetration ratio, plant area index (PAI), flag for voids |
| Applications |
|---|
| • voxel-based analysis of point clouds |
| • vegetation analyses (density/transparency) |
| • filled and empty space analyses |
Tool: Voxelize Point Cloud
| Features |
|---|
| • creation of a voxelized representation of a point cloud based on a given voxel system |
| • update of a voxelized representation of a point cloud with further voxel measures |
| • labeling of a point cloud by voxel identifier |
| • output of either all voxels, filled voxels or only empty voxels |
| • calculation of statistical measures of attributes per voxel (n, minimum, maximum, range, sum, mean, standard deviation, median, majority) |
| • optional: neighborhood analysis on the 6-, 18- or 26-connected voxels |
| Applications |
|---|
| • voxel-based analysis of point clouds and their attributes |
| • computation of statistical measures |
| • filled and empty space analyses |